Back to Products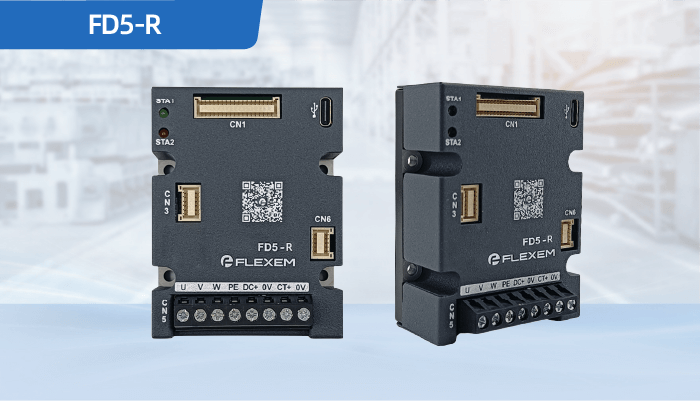
FLEXEMSERVO
FD5 Series
Low-Voltage DC Servo
FD5 series high-performance servo products are designed for small loads and high precision applications, such as packaging industry, AGV vehicles, etc. 17/23bit multi-turn absolute low-voltage motor, general low-voltage rotary servo, DDR, DDL, voice coil motor, support EtherCAT, Modbus communication protocols, pressure control, 16-bit high-precision analog, full closed-loop function, high-speed DI/DO, Type-C debugging.
Manufacturer product pageDescription
FD5 Low Voltage Servo Driver Multiple Magnetic Pole Configurations Supports Rotary and Direct Drive Motors 12-110VDC Power Supply
Specifications
| FD5-*1-64* | FD5-*1-N6410 | FD5-*1-N6406 | FD5-*1-N6403 | FD5-*1-P6410 | FD5-*1-P6406 | FD5-*1-P6403 |
|---|---|
| Power Supply | Main loop power input | 12-64VDC (When only the main circuit is input, the drive can work normally, but it cannot be powered off the main circuit alone.And keep the drive in a communicable state) |
| Control loop power input | 12-64VDC (When only the control power is input, the drive can be powered on self-test, communication, etc., but cannot be enabled) |
| Rated current (A)(Arms) | 10.0 | 6.0 | 3.0 | 10.0 | 6.0 | 3.0 |
| Maximun current(Arms) | 25.0 | 16.9 | 9.0 | 25.0 | 16.9 | 9.0 |
| Control mode | Motor | Motor type | Low voltage DDR motor, low voltage DDL motor, voice coil motor, low voltage rotary servo motor |
| Magnetic pole identification method | Low voltage DDR motor, low voltage DDL motor, voice coil motor, low voltage rotary servo motor |
| Automatic configuration | Support communication encoder power-on automatically read, configure motor parameters; Support independent encoder and third-party encoder switching; Supports phase sequence identification |
| Operation mode | Optional mode | Torque mode, speed mode, position mode, (open/closed loop) force control mode |
| Torque control | Torque control bandwidth | 4.5K |
| Command source | Analog, EtherCAT, internal command |
| Current control accuracy | ±0.5%Rated output current |
| Speed control | Speed control bandwidth | 3K |
| Internal speed control refresh cycle | 16K |
| Control method | PI adjustment, torque feedforward, friction compensation, loop filtering, etc |
| Command source | Analog, Ethercat, internal multiple speed |
| Position control | The internal position controls the refresh cycle | 4K |
| Control method | Proportional adjustment, speed feedforward, command smoothing, etc |
| Command source | Pulse, EtherCAT, internal multisegment position |
| IO | AI | High precision AI | 1 channel, ±10VDC differential, resolution 16bit; Can be used for closed loop force control |
| DI | Standard DI | 3-channel fast DI (P-type machine is 4 channels), directly connected to FPGA, photoelectric isolation, support NPN/PNP mode |
| High speed DI | 2 ultra-high speed DI, directly connected to FGPA, photoelectric isolation, support NPN/PNP mode |
| DO | Standard DO | 4-channel fast DO (P-type machine for 4), directly connected to FPGA, photoelectric isolation, NPN, maximum load 50mA |
| Pulse & Direction | When * is P, P type machine, P type machine support pulse signal input control (including differential form, OC form); Maximum input frequency 4MHz (OC form is 200K) |
| Communication Interface | EtherCAT communication | When * is N, N type machine, N type machine support EtherCAT communication control, minimum communication cycle 250us |
| Background debugging communication port | 1 USB Type C port, used for software debugging of the drive |
| RS485 communication port | When it is a P-type machine, 1: n communication up to 31 axes can be performed |
| Encoder (Motor Feedback Signal) Interface | Communication type coding port | FD5-U series: RS485, support Tamagawa protocol, FLEXEM protocol, BISS C protocol; Maximum baud rate 4M, FD5-R series: RS485, support Tamagawa protocol, Maximum baud rate 4M |
| Dart line differential encoder port | ABZ, Maximum input frequency 5MHz; Can be used as a second encoder input for full closed loop applications; R series without the second interface |
| Hall port | Single-ended NPN mode |
| Motor temperature sensor interface | Supported, thermistor PTC/NTC; R series without the PTC/NTC |
| Status Indicator | STA1_LED | Indicates the operating status of the drive |
| STA2_LED | Indicates drive failure status |
| Protection function | Protection function | Input voltage undervoltage and overvoltage, driver overcurrent, overload, input short circuit to the ground protection, motor overload, high temperature protection, overrange,The position deviation is too large, the second encoder is missing, the car protection, the main circuit self-diagnosis of power-on, etc |
| Meet certificate standard | Under way |
| Environmental requirement | Environment | Ambient temperature | Operating temperature: 0-55℃: Storage temperature : -20-85℃ |
| Ambient humidity | Ambient humidity:10-90% |
| Shock resistance | Shock: 1.0g |
| Altitude | Altitude: < 2000m |
| Pollution level | PD2 |
| Prohibited working environments | Working environment with corrosive or combustible gases, chemicals or oily water, iron and salt containing dust |
| Protection level | IP20 |
| Size | 57.5*75.5*25.4mm |