Back to Products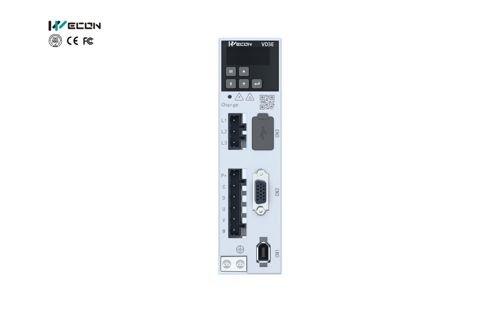
Description
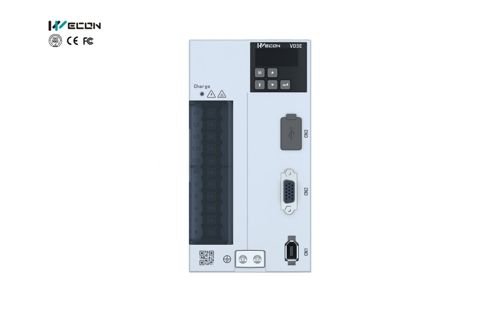
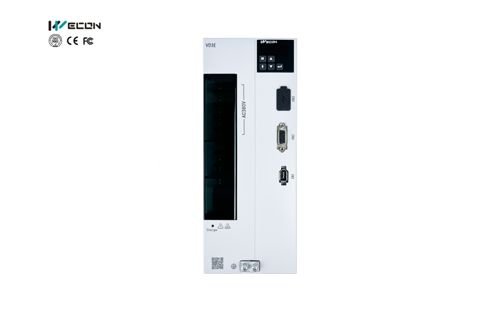
EtherCAT bus servo drive with strong device compatibility. | Dual-board design structure, separation of high and low voltage circuits for more stable operation. | Multiple control modes to meet diverse and complex applications.
Specifications
| Type | Voltage and Current |
|---|---|
| VD3E-010SA1G | Input voltage: 220V, Maximum output current: 10A |
| VD3E-014SA1G | Input voltage: 220V, Maximum output current: 14A |
| Specifications | VD3E(A Type) |
| Basic Specifications | Power supply | 220V |
| Control method | IGBT PWM control sine wave current drive |
| Encoder | 17bit, 23bit absolute value encoder |
| Control signal input | 6DI, Select the input function according to the function code configuration |
| Control signal output | 3DO, Select the output function according to the function code configuration |
| Communication | Host computer communication | The USB interface can be used to set function code parameters, monitor status, view waveforms, and perform parameter self-tuning, etc. via a computer host. |
| Braking resistor | Internal braking resistor(also support external braking resistor) |
| General functions | Auto-tuning | Automatic load inertia identification, automatic rigidity self-tuning (SCTool) |
| Waveform monitoring | Monitor real-time speed/torque/position(SCTool) |
| Waveform recording | Waveform acquisition frequency 1K Hz,10s waveform data recording |
| Parameter management | Support batch parameter import and export; Support SDO modification |
| Vibration suppression | Support mechanical vibration suppression |
| Protection | Overvoltage, undervoltage, overcurrent, overspeed, overload, overheating, encoder failure, excessive position deviation, torque limit, speed limit, etc. |
| Brake device | Support brake signal output |
| DI function | Error/alarm clear(A-CLR), Forward rotation prohibited(POT)Backward rotation prohibited(NOT), Emergency stop(E-STOP) |
| DO function | Servo ready(RDY)、Error signal(ALM), Alarm signal(WARN), Rotation detection(TGON) Zero speed signal(ZSP), Torque limited(T-LIMIT), Velocity limited(V-LIMIT) Servo start(SRV-ST), Servo brake output(BRK-OFF), Communication VDO |
| EtherCAT related | EtherCAT related | Communication protocol | EtherCAT protocol |
| Support services | CoE(PDO,SDO) |
| Sync mode | DC-Distributed Clock |
| Physical layer | 100BASE-TX |
| Baud rate | 100 Mbit/s(100Base-TX) |
| Duplex mode | Full duplex |
| Topology | Circular, linear |
| Transmission medium | Shielded Category 5e or better network cable |
| Transmission distance | Less than 100M between two nodes (good environment, good cables) |
| Frame length | 44 bytes to 1498 bytes |
| Excessive data | Maximum size of a single Ethernet frame is 1486 bytes |
| Sync jitter | <1μs |
| Distributed clock | 64 bit |
| EEPROM capacity | 8k bit initialization data is written through the EtherCAT master station |
| Control mode and performance | Control mode | CSP、HM、CSV、CST、PT |
| Sync period | 125μs |